Impedance Control on Haptic Paddle
Last updated: less than 1 minute read
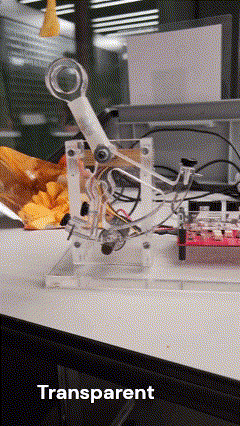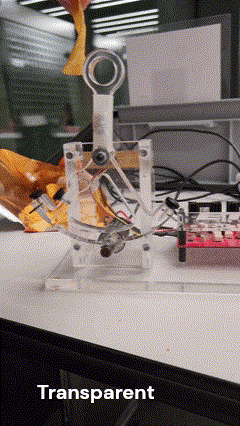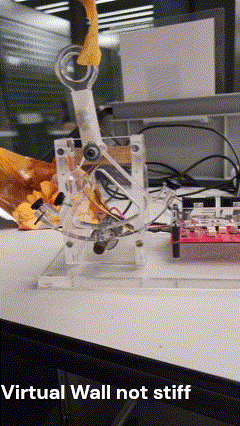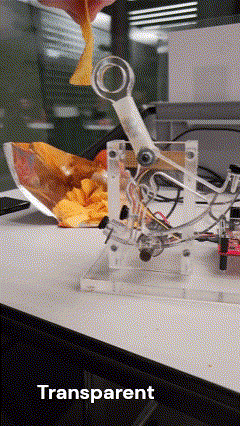
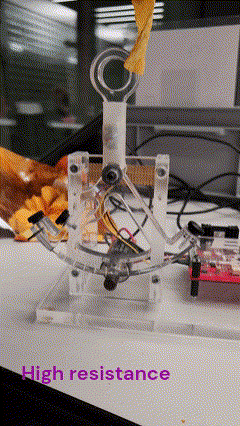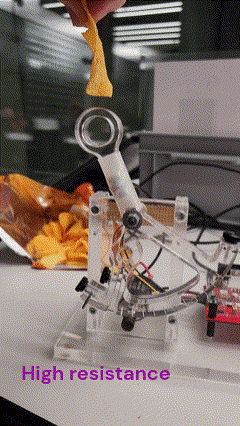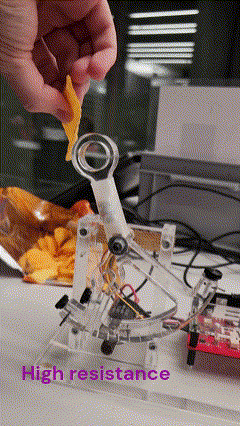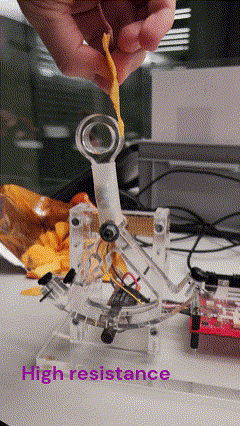
This is a course project for Physical Human-Robot Interaction at ETHZ. We implemented impedance control with model feedforward and force feedback on the haptic paddle to achieve transparency. We also analyzed stiffness of virtual walls.
Without model feedforward or force feedback:
With model feedforward and force feedback: